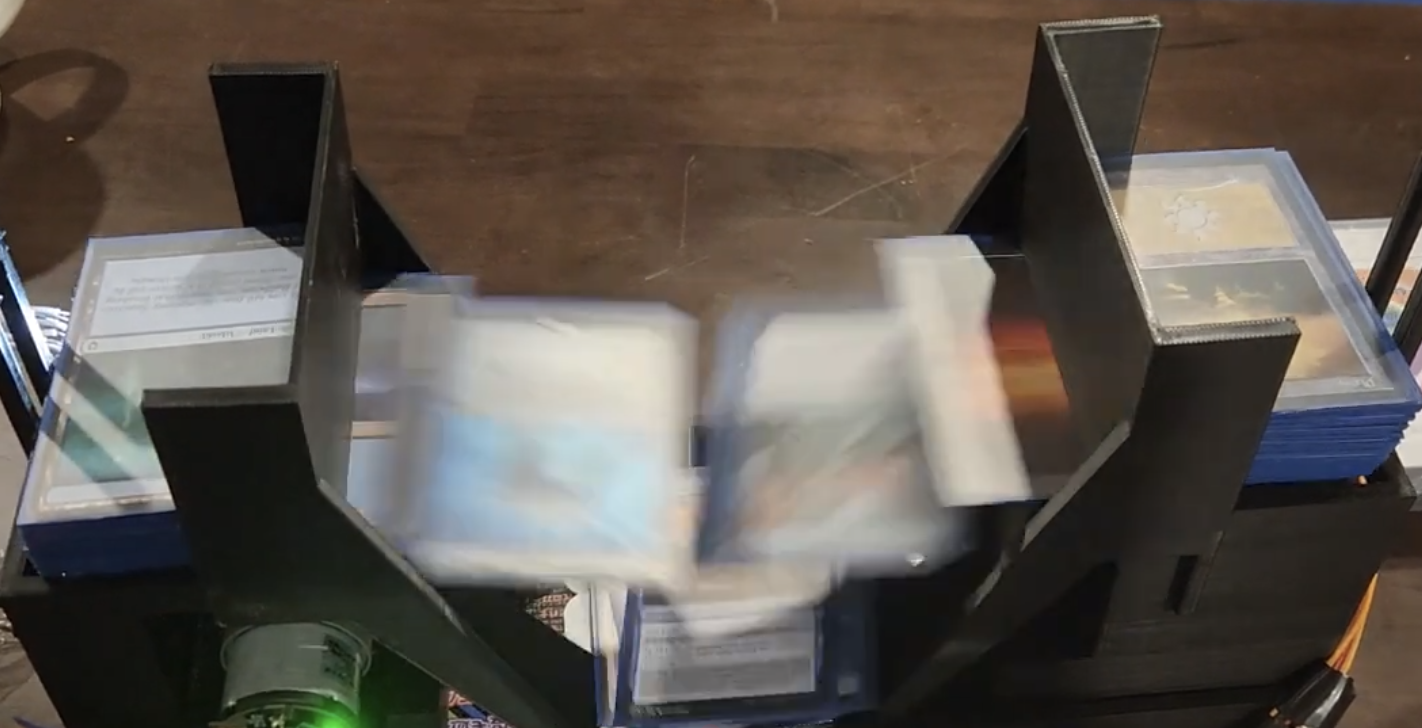
This is an Automatic Card Shuffler I built as a personal project for the trading card game Magic: The Gathering. The system uses an ultrasonic sensor to detect the presence of the cards, and uses 2 flywheels attached to DC motors to spin the cards into the middle pile. The system automatically stops when it detects that all cards have been shuffled. I personally did all the CAD prototyping, the electrical circuit design, and the programming. I later furthered this project by expanding upon it for Senior Capstone.
Video Link: https://www.youtube.com/watch?v=cs_fdS0fooY
Capstone Final Report: View PDF
Tools/Skills used: STM32, I2C, C, SolidWorks, 3D-Printing, Electrical System Testing, Soldering
Self-Stabilizing Airflow Tube
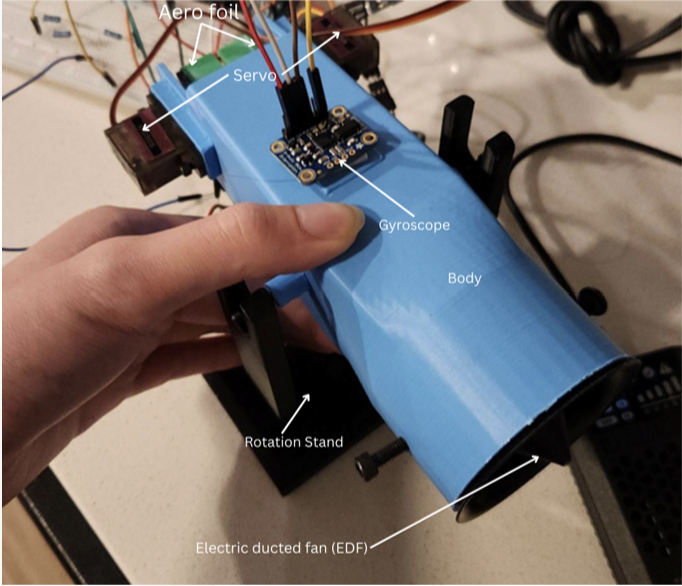
A group project made for a controls class at Georgia Tech. The project served as an attempt to recreate several controls principles learnt in class. The system blows air into the tube via an intake fan and airfoils at the back adjust to keep the tube maintained at a fixed angle. A gyro sensor with 2 servos are used to implement the lead controller tuned with loop shaping.
Link to Powerpoint: View Slides
Tools/Skills used: Control Systems Design, 3D Printing, Soldering, C++, Arduino, CAD
League of Legends Championship Predictor
Created a ML model to predict the winner of the 2024 League of Legends World Championship for a class project. After processing data from an entire season of games, I passed the data through a prediction pipeline made up of a Logistic Regression, a Random Forest, and a LSTM Model. The model achieved a 90%+ accuracy in determing game victors based on match statistics and overall produced an average ranking deviation of 2.5 for the final team placements.
Detailed Video: https://www.youtube.com/watch?v=rhbuzXaauHI
Tools/Skills used: Excel, PyTorch, TensorFlow, Data Processing, Sklearn, Github, Pandas, Python, Keras
ME2110 Robotics Competition
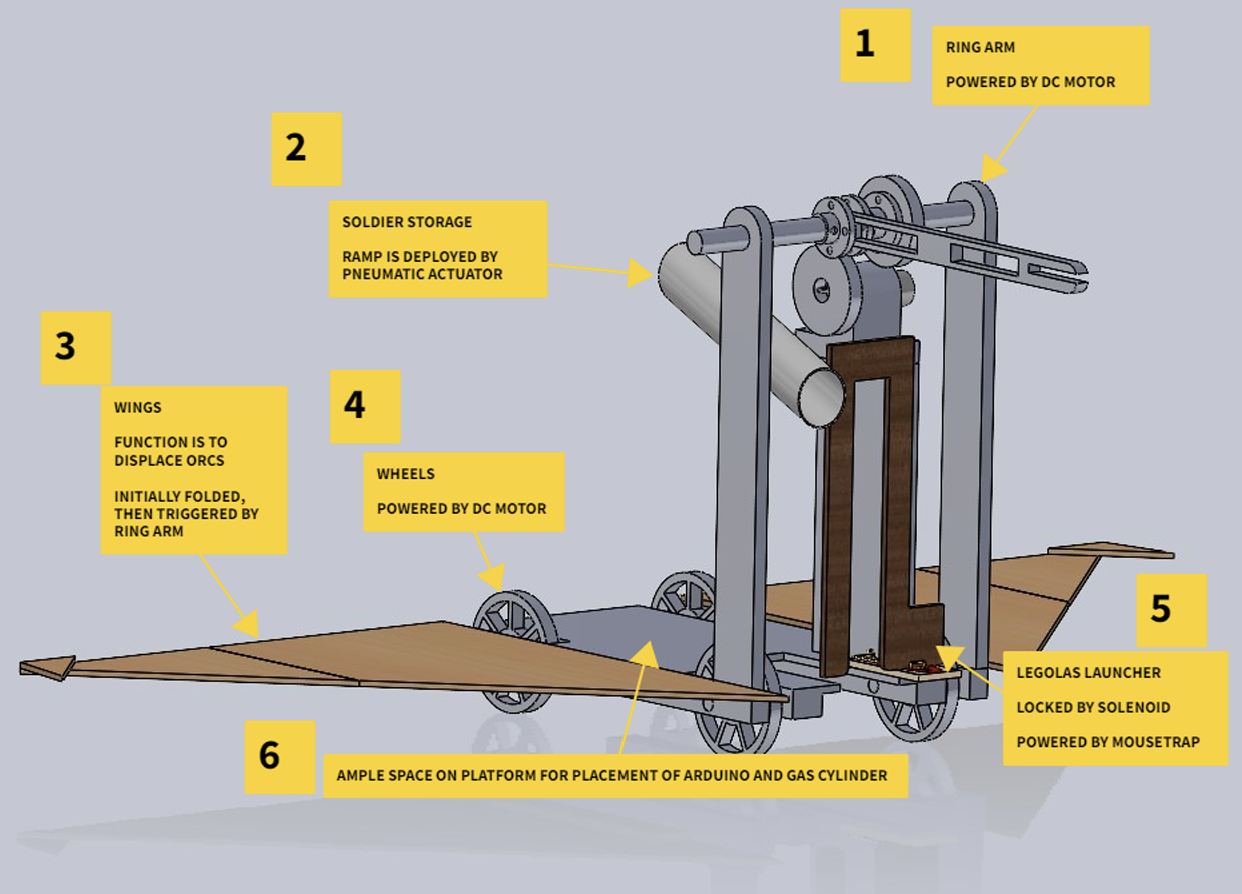
This project was for a robotics competition for the Georgia Tech ME2110 Design Competition class. The competition rules required a fully autonomous system with a limits on budget, size, and number of actuators. My team and I went through the entire product development lifecycle from start to finish to create a robot that finished top 16 in the class.
Full Report: View PDF
Tools/Skills used: Machining, Prototyping, SolidWorks, BoM, C++, HoQ, Arduino, CAD
Swan-Neck Mount for HyTech Racing
Work in Progress
Radio Board Redesign for RoboWrestling
Work in Progress
3D Printer Undetectable Geometric Attack
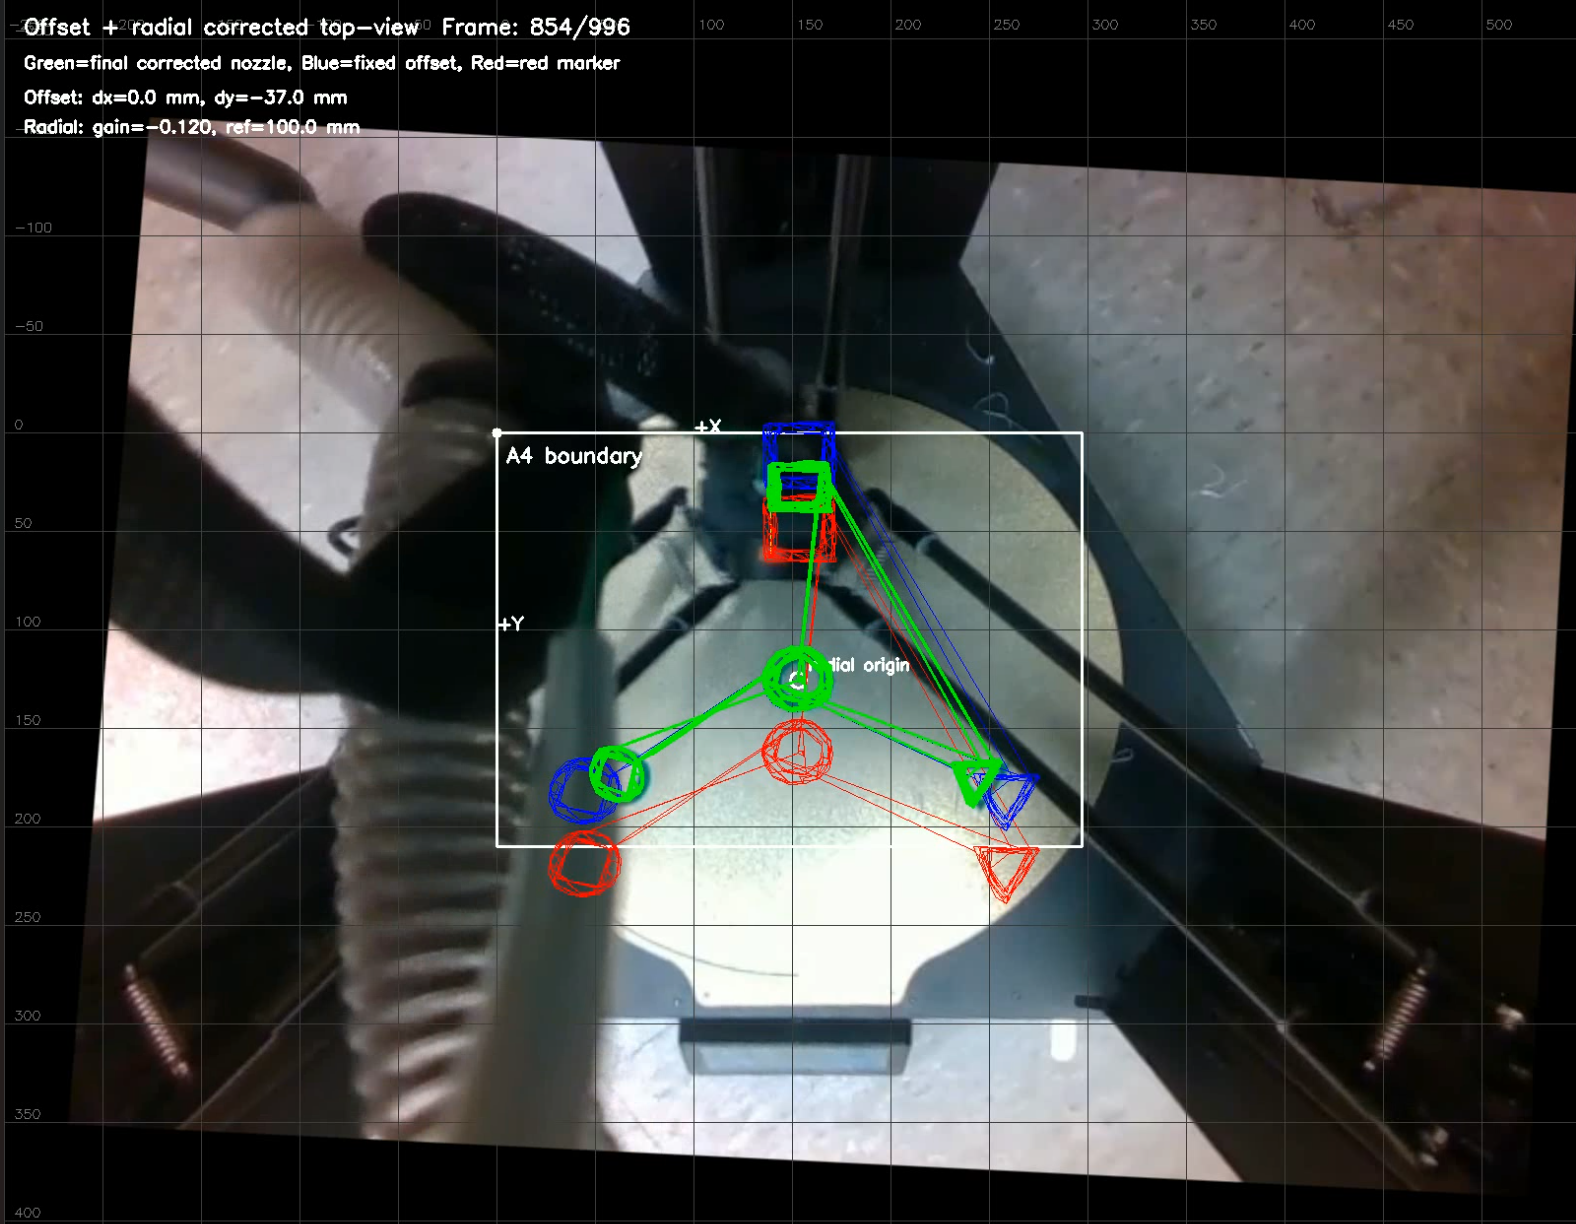
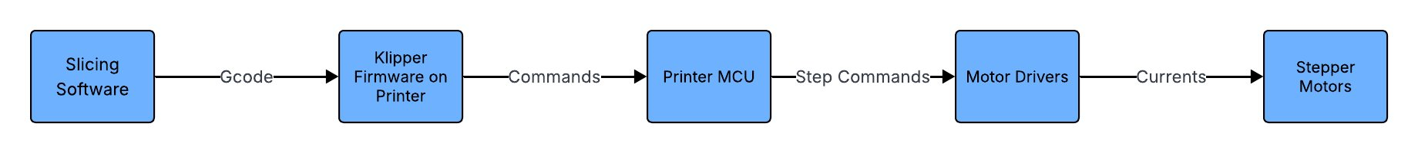
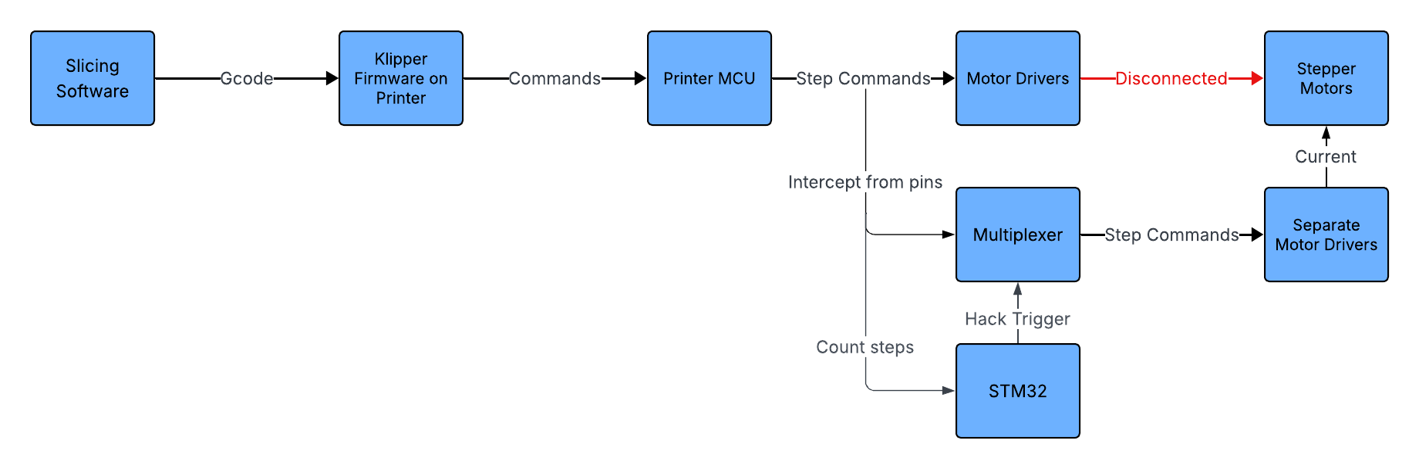
Worked on a project in Dr Jun Ueda's lab to prove a fundamental flaw in a Delta Parallel Robot allowing for undetectable attacks on 3D Printers with similar configuration. The project involved tearing apart an FLSUN 3D printer in order to implement a physical hardware attack which would replicate a theoratically possible software attack. Step signals from the PCB were rewired to a hack board and then back to their subsequent motors in order to implement the hack. Paper to be published soon.
Tools/Skills used: Oscilloscope, Multimeter, STM32, SPI, C, Gcode, Mechatronics